Background Extraction
The sky background often has an unwanted gradient caused by light pollution, the moon, or simply the orientation of the camera relative to the ground. This tool models that gradient and removes it, following a smooth function so that nebulae and other real signal are preserved.
Siril offers two methods to build the background model, selected with the Method drop-down at the top of the dialog:
Sample-based (the classic method): the background is sampled at many places of the image, either on a regular grid or at manually placed points, and a smooth surface is interpolated through those samples.
Automatic (sample-free): no samples are placed. The background is fitted directly on every pixel that survives an iterative robust rejection of structures (stars, nebulae), which makes it convenient when placing a good sample grid is difficult.
The Correction mode, the Compute Background button and the View selector (see General settings) are common to both methods. All the other options are specific to the method selected.
Sample-based method
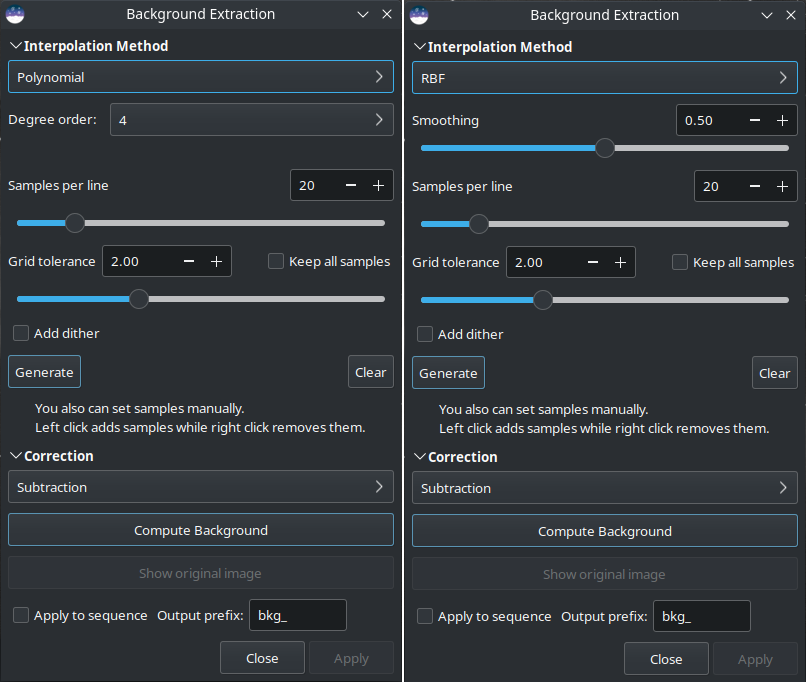
Background extraction dialog box. On the left is the polynomial version, on the right RBF.
Samples can be automatically placed by providing a density (Samples per line) and clicking on Generate. If areas of the image are brighter than the median by some factor Grid tolerance times sigma, then no sample will be placed there.
There are some options regarding how to place samples.
The default is a regular grid, however you can select random sample locations to achieve the same sample positioning as SetiAstro's AutoDBE process.
You can select sample optimization. If this is enabled, the position of each sample will be optimized by seeking a local minimum sample median. This may result in an irregular grid. Note that this setting also affects manually placed samples, so don't be surprised if your samples move! If you wish to place a sample precisely then disable this.
You can also limit the area in which samples are placed. If a sample lands too close to the image edge it may include black border areas, or areas of uneven coverage, resulting in a poor background model. By making a selection a little in from the image edge, you can restrict the sample placement to inside the selection thus eliminating the problem with edge samples.
Tip
If you have very strong gradients, for example when imaging in high Bortle urban skies, even the maximum grid tolerance may be insufficient. In this case you can check the Keep all samples checkbox and the full sample grid will be populated. You will then need to remove samples from actual astronomical objects manually.
After generation, samples can also be added manually (left click) or removed manually (right click).
Add dither: check this option when color banding is produced after background extraction. Dither is an intentionally applied form of noise used to randomize quantization error, preventing large-scale patterns such as color banding in images.
There are two algorithms to interpolate the background model through the samples:
RBF
This is the most modern method. It uses the radial basis function to synthesize a sky background to remove the gradient with great flexibility. It requires a single parameter which is present in the form of a slider: Smoothing. With this value you can determine how soft or hard the transition between the sample points is calculated. A high smoothing factor makes sense for large and uniform gradients, and a correspondingly lower value for small, local gradations.
Tip
Start with the basic setting (50%) and gradually tweak for optimal results.
Theory
Radial basis functions are functions of the form \(\phi(\mathbf{x}) = \phi(\| \mathbf{x} \|)\), whereby in our case we use the Euclidean norm \(\| \mathbf{x} \| = \sqrt{x_1^2 + x_2^2}\). The function \(f\), which describes the background model, can now be expressed as a linear combination
where \(w_i\) corresponds to the weights for the different sample points and \(o\) corresponds to a constant offset.
The requirement that the function \(f\) should pass through the sample points results in the condition
which can only be fulfilled if the matrix on the left-hand side is invertible. With the right choice of function \(\phi\) this can always be guaranteed [Wright2003].
In addition, the summand \(s \, I\) is added to the matrix on the left-hand side, where \(s\) is a smoothing parameter and \(I\) is the unit matrix. The summand causes a regularization, which results in a smoother result the larger the parameter \(s\) is. This parameter can be changed with the Smoothing parameter of the dialog box.
For the radial basis function, we use the thin-plate spline \(\phi(|\mathbf{x}|) = |\mathbf{x}|^2 \log(|\mathbf{x}|)\).
Polynomial
This is the original and simplest algorithm developed in Siril. Only one parameter is used in polynomial computation: the Degree order. The higher the degree, the more flexible the correction, but a too high degree can give strange results like overcorrection.
Tip
A degree 1 correction can be very useful for when you want to remove the gradient on the subs.
Warning
Background removal can be carried out on CFA images, but only if they have Bayer patterns. (It is not supported for X-TRANS patterns.) For Bayer patterned images, the image is treated as four spatially interleaved images, each corresponding to a CFA subchannel. Each subchannel is independently processed to remove its gradient and then the subchannels are recombined into the original interleaved pattern.
The intended use for this is to remove linear gradients from sequence frames prior to using Drizzle on a Bayer patterned sequence, and in that case it is strongly recommended to use linear (polynomial order 1) gradient removal as with other pre-stacking gradient removal.
Theory
Polynomial functions are functions of the form
In Siril, the maximum degree allowed is \(n=4\) and can be modified using the Degree order drop-down menu. Beyond this, the model is generally unstable and gives poor results.
Automatic (sample-free) method
When Automatic (sample-free) is selected in the Method drop-down, no samples are placed on the image. Instead, the background is fitted directly on the pixels: the tool iteratively rejects everything that does not look like background (stars, nebulae and other structures) and fits a smooth model on the pixels that remain. This is convenient when a good sample grid is hard to place, for example on densely populated fields.
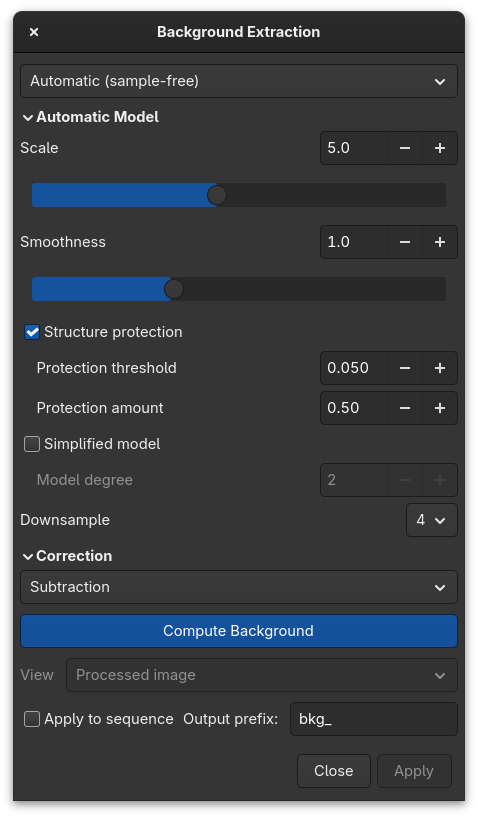
Background extraction dialog with the automatic (sample-free) method selected, showing the Automatic Model panel.
Warning
The automatic method fits the background over the whole image, borders included. Stacked images very often have black or uneven edges (caused by dithering, field rotation or incomplete overlap between frames). These borders must be cropped away before running the automatic method, otherwise they are treated as extremely dark background and corrupt the model. Unlike the sample-based method, the edges cannot be excluded here by making a selection, so a clean crop of the stacked result is imperative.
The following parameters are available in the Automatic Model panel:
Scale: relative scale of the multiscale model, in the
[1, 10]range (default 5). A higher value keeps only large-scale gradients and gives a smoother model, while a lower value lets the model follow more complex or more local gradients.Smoothness: extra smoothing applied to the final model (default 1). A higher value gives a softer, more gradual background; a value of 0 leaves the fitted model untouched.
Simplified model: disabled by default. When enabled, a stiff low-degree polynomial is fitted and removed before the multiscale model, which is then fitted on what the polynomial leaves behind; the background finally removed from the image is the sum of the two. It helps on strong, complex gradients whose amplitude rivals or even exceeds the objects of interest, a case where a single pass cannot tell them apart and ends up modelling the objects themselves. Conversely it can be counterproductive on a frame holding a large, bright object, which the polynomial may partly absorb, leading to overcorrection.
Model degree: degree of that polynomial, in the
[1, 6]range (default 1, which is a plane). A lower value is stiffer. Raise it for a gradient with real curvature, keeping in mind that a large bright object is then more easily absorbed by it.
Structure protection: when enabled (the default), extended bright structures such as nebulae are masked so that they are not absorbed into the background model. It applies to the simplified model too, when that one is enabled. Two sub-parameters control it:
Protection threshold: brightness above the model at which a pixel starts to be treated as a structure (default 0.05). A lower value protects more of the image.
Protection amount: how far the protection mask grows around the detected structures (default 0.5).
Downsample: internal working scale factor (1, 2, 4 or 8, default 4). A higher value makes the computation faster but coarser; it does not change the scale of the background itself.
Tip
Start with the default settings. If real signal (a large nebula) is being eaten by the model, lower the Protection threshold. If instead the gradient itself is so strong that its amplitude is comparable to the objects — bright urban skies, a strong moon gradient — enable the Simplified model and leave Model degree at 1.
Theory
The automatic model is estimated independently on each channel and, for speed, on an internally downsampled copy of the image (the Downsample factor). It then alternates a fit step and a robust rejection step:
An initial background model \(B\) is fitted on every pixel.
The residual \(r = I - B\) between the image \(I\) and the current model is computed, and its robust location and scale are estimated from the pixels currently kept, using the median and the median absolute deviation (\(\sigma = 1.4826 \times \mathrm{MAD}\)).
Pixels are rejected by an asymmetric sigma clipping: a pixel is kept only if its residual lies within \([\,\mathrm{med} - k_\mathrm{lo}\,\sigma,\ \mathrm{med} + k_\mathrm{hi}\,\sigma\,]\), with a tighter upper bound than the lower one. Bright outliers (stars, nebula cores) are therefore discarded more aggressively than faint ones.
When Structure protection is enabled, a spatially-coherent mask of extended bright structures is additionally removed from the fitting set, so large nebulae are not mistaken for background.
The model is re-fitted on the surviving pixels and the process repeats until the kept set stabilises.
The surface fitted at each iteration is a multiscale model: it is rebuilt across the rejected regions by harmonic-style inpainting (repeated low-pass filtering that restores the kept pixels at each pass); the Scale parameter sets the width of that low-pass, i.e. the spatial scale below which variations are considered signal rather than background. A final, optional Gaussian smoothing is controlled by Smoothness.
When Simplified model is enabled, that whole procedure is run twice. The first pass fits a single 2D polynomial of the chosen Model degree by least squares instead of the multiscale surface, and removes it from the working image; the second pass fits the multiscale surface on the remainder, and the two are added back together to form the background that is subtracted from (or divided into) the image. The gain is not merely that the overall tilt is gone beforehand: both the \(\sigma\) the rejection clips on and the absolute Protection threshold are then measured on a flattened image instead of on the gradient, so they behave as intended from the very first iteration rather than being dominated by the gradient itself. Being stiff, the polynomial cannot follow — and therefore cannot hollow out — a structure that the multiscale surface would absorb; conversely a large, smooth object is itself close to a low-order polynomial, which is exactly why a high Model degree can eat it.
The low-pass filtering relies on a fast separable Gaussian approximated by variance-matched box blurs, so its cost is independent of the smoothing radius.
General settings
These controls sit below the method panels and apply whichever method is selected.
Correction:
Subtraction: it is mainly used to correct additive effects, such as gradients caused by light pollution or by the Moon.
Division: it is mainly used to correct multiplicative phenomena, such as vignetting or differential atmospheric absorption for example. However, this kind of operation should be done by master-flat correction.
Compute Background: This will compute the synthetic background and will apply the selected correction. The model is always computed from the original image kept in memory allowing the user to work iteratively. The result is only previewed at this stage; it is committed when you close the dialog with the Apply button.
View: once a background has been computed, this drop-down chooses what is shown in the main view without recomputing anything:
Processed image: the corrected result (the default).
Background model: the background that was removed, reconstructed from the original and the processed image.
Original image: the untouched image kept in memory.
This replaces the former Show original image button and works identically for both methods.
The background gradient of pre-processed image can be complex because the gradient may have rotated with the acquisition session. It can be difficult to completely remove it, because it’s difficult to represent it with a polynomial function. If this is the case, you may consider removing the gradient in the subexposures: in a single image, the background gradient is much simpler and generally follows a simple linear (degree 1) function.
Tip
Sometimes unsightly color banding appears after background extraction. When this happens, there are two things to check. Firstly, if the image is in 16-bit, we strongly advise you to always use the 32-bit format. If, despite everything, you still observe such artifacts, the add dither option, explained above, is the solution to your problem.

When such banding occurs after gradient extraction. It can be solved with the add dither option (Courtesy of Nathan B.).
Tip
Good results with the RBF algorithm generally require fewer samples than with the polynomial algorithm.
See also
For more explanations, see the corresponding tutorial here.
Siril command line
subsky { -rbf | degree | -auto } [-dither] [-samples=20] [-tolerance=1.0] [-smooth=0.5] [-existing] [-random] [-gradient] [-border=<pixels|percent%>] [-scale=5] [-smoothness=1] [-noprotect] [-protect_threshold=0.05] [-protect_amount=0.5] [-simplified] [-degree=1] [-downsample=4] [-mode=subtract|divide]
Tip
The automatic (sample-free) method is available on the command line with the
-auto argument. In this mode the sample-related options are ignored and
the automatic-model parameters (-scale=, -smoothness=, -noprotect,
-protect_threshold=, -protect_amount=, -simplified, -degree=,
-downsample=) apply instead, together with -mode=subtract|divide for
the correction type. See the subsky reference above for the
full list.
Tip
The -existing command argument forces use of existing background samples.
This option is primarily for use in conjunction with the Python module where
SirilInterface.set_bgsamples() can be used to set custom background
samples based on user-defined algorithms. If it is not provided, subsky
will automatically regenerate background samples. Note that the -existing
option is not available with the seqsubsky command, because sequence frames
are not necessarily registered at the time background subtraction is carried
out, so the samples for one frame do not necessarily apply to another.
Siril command line
seqsubsky sequencename { -rbf | degree | -auto } [-nodither] [-samples=20] [-tolerance=1.0] [-smooth=0.5] [-prefix=] [-random] [-gradient] [-border=<pixels|percent%>] [-scale=5] [-smoothness=1] [-noprotect] [-protect_threshold=0.05] [-protect_amount=0.5] [-simplified] [-degree=1] [-downsample=4] [-mode=subtract|divide]
Wright, Grady Barrett. Radial basis function interpolation: numerical and analytical developments. University of Colorado at Boulder, 2003.